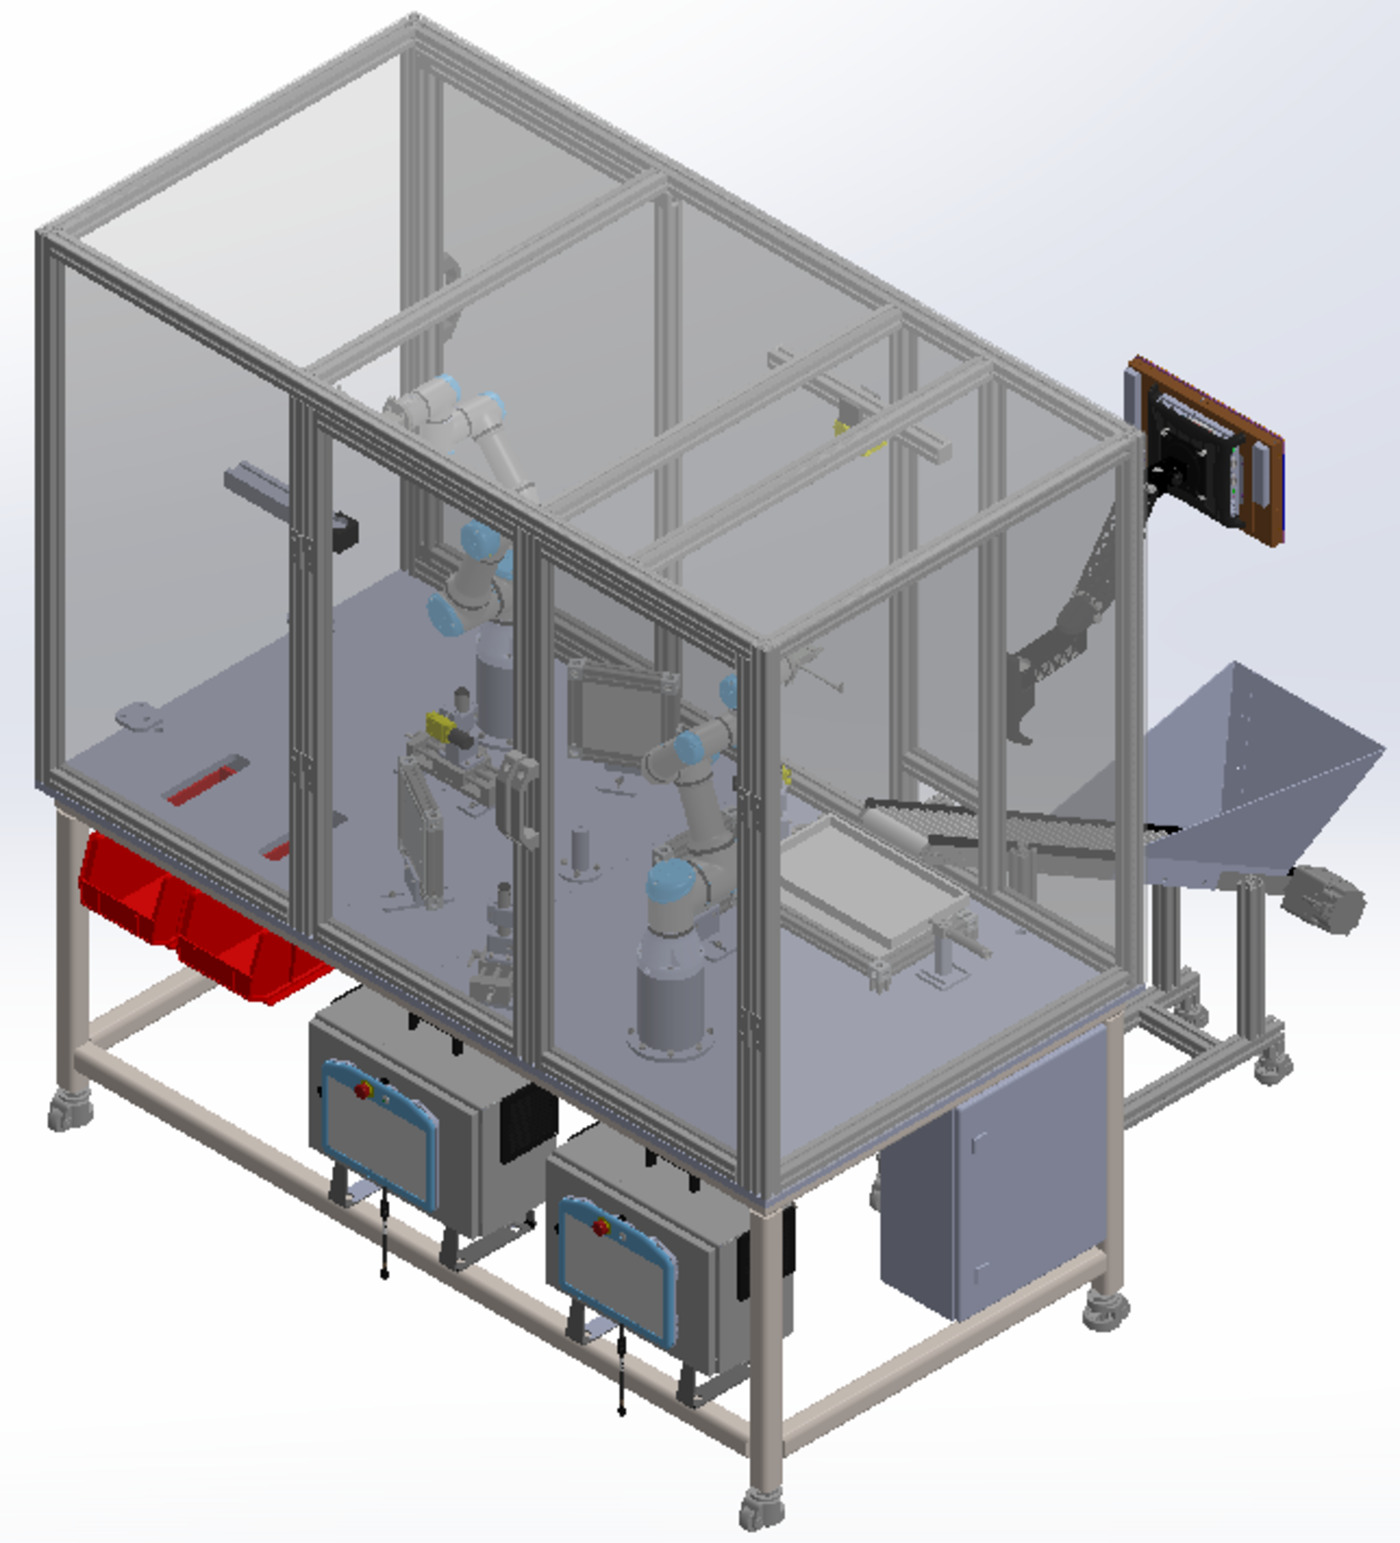
This was a machine that I was key in the development of. It is a modular, 360-part inspection cell utilizing 2 robots, that attaches to the following process. The machine has a cleanroom wipedown design with variable components depending on application needs. We have since productized this design for cylindrical objects to impact more industries, past being a one-off machine.
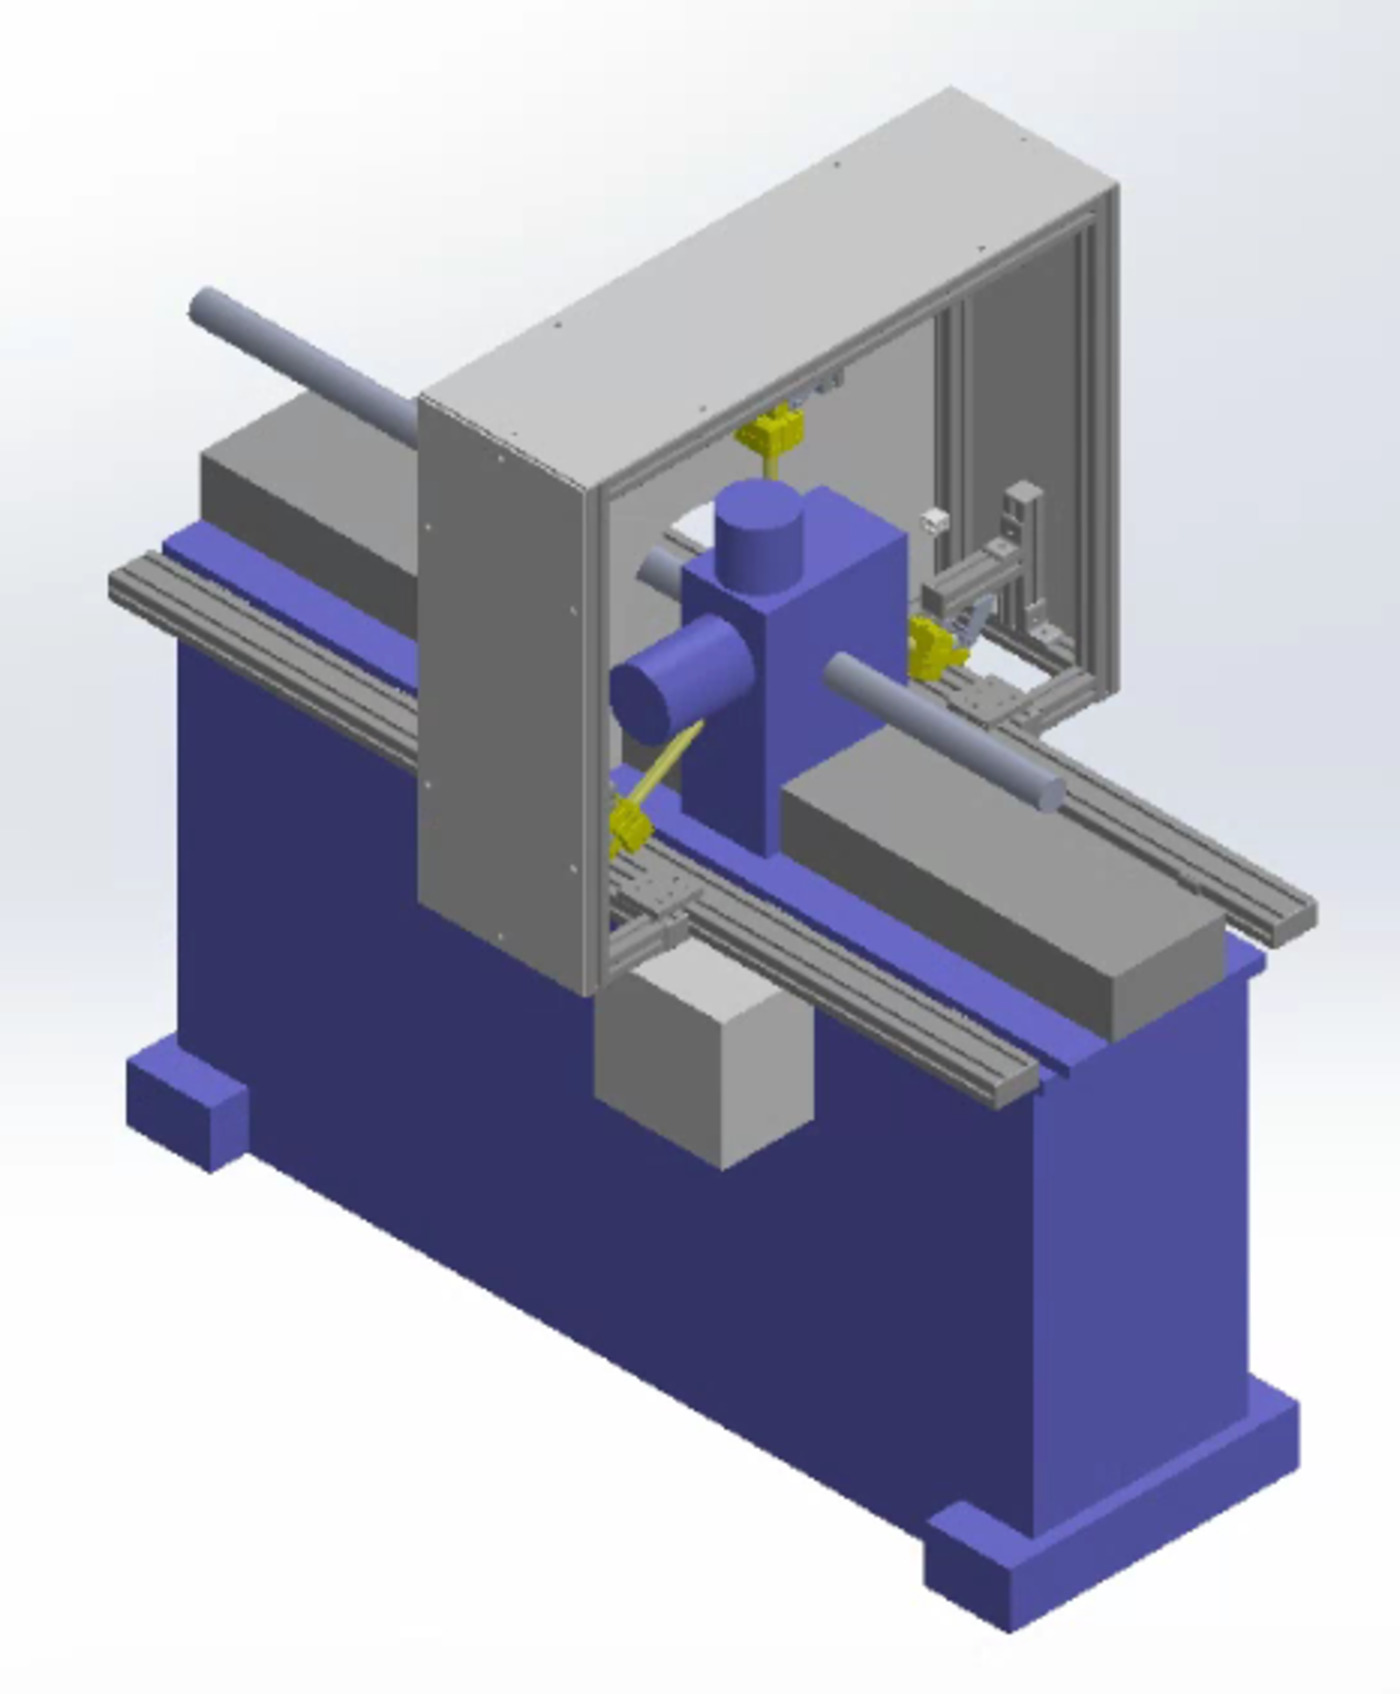
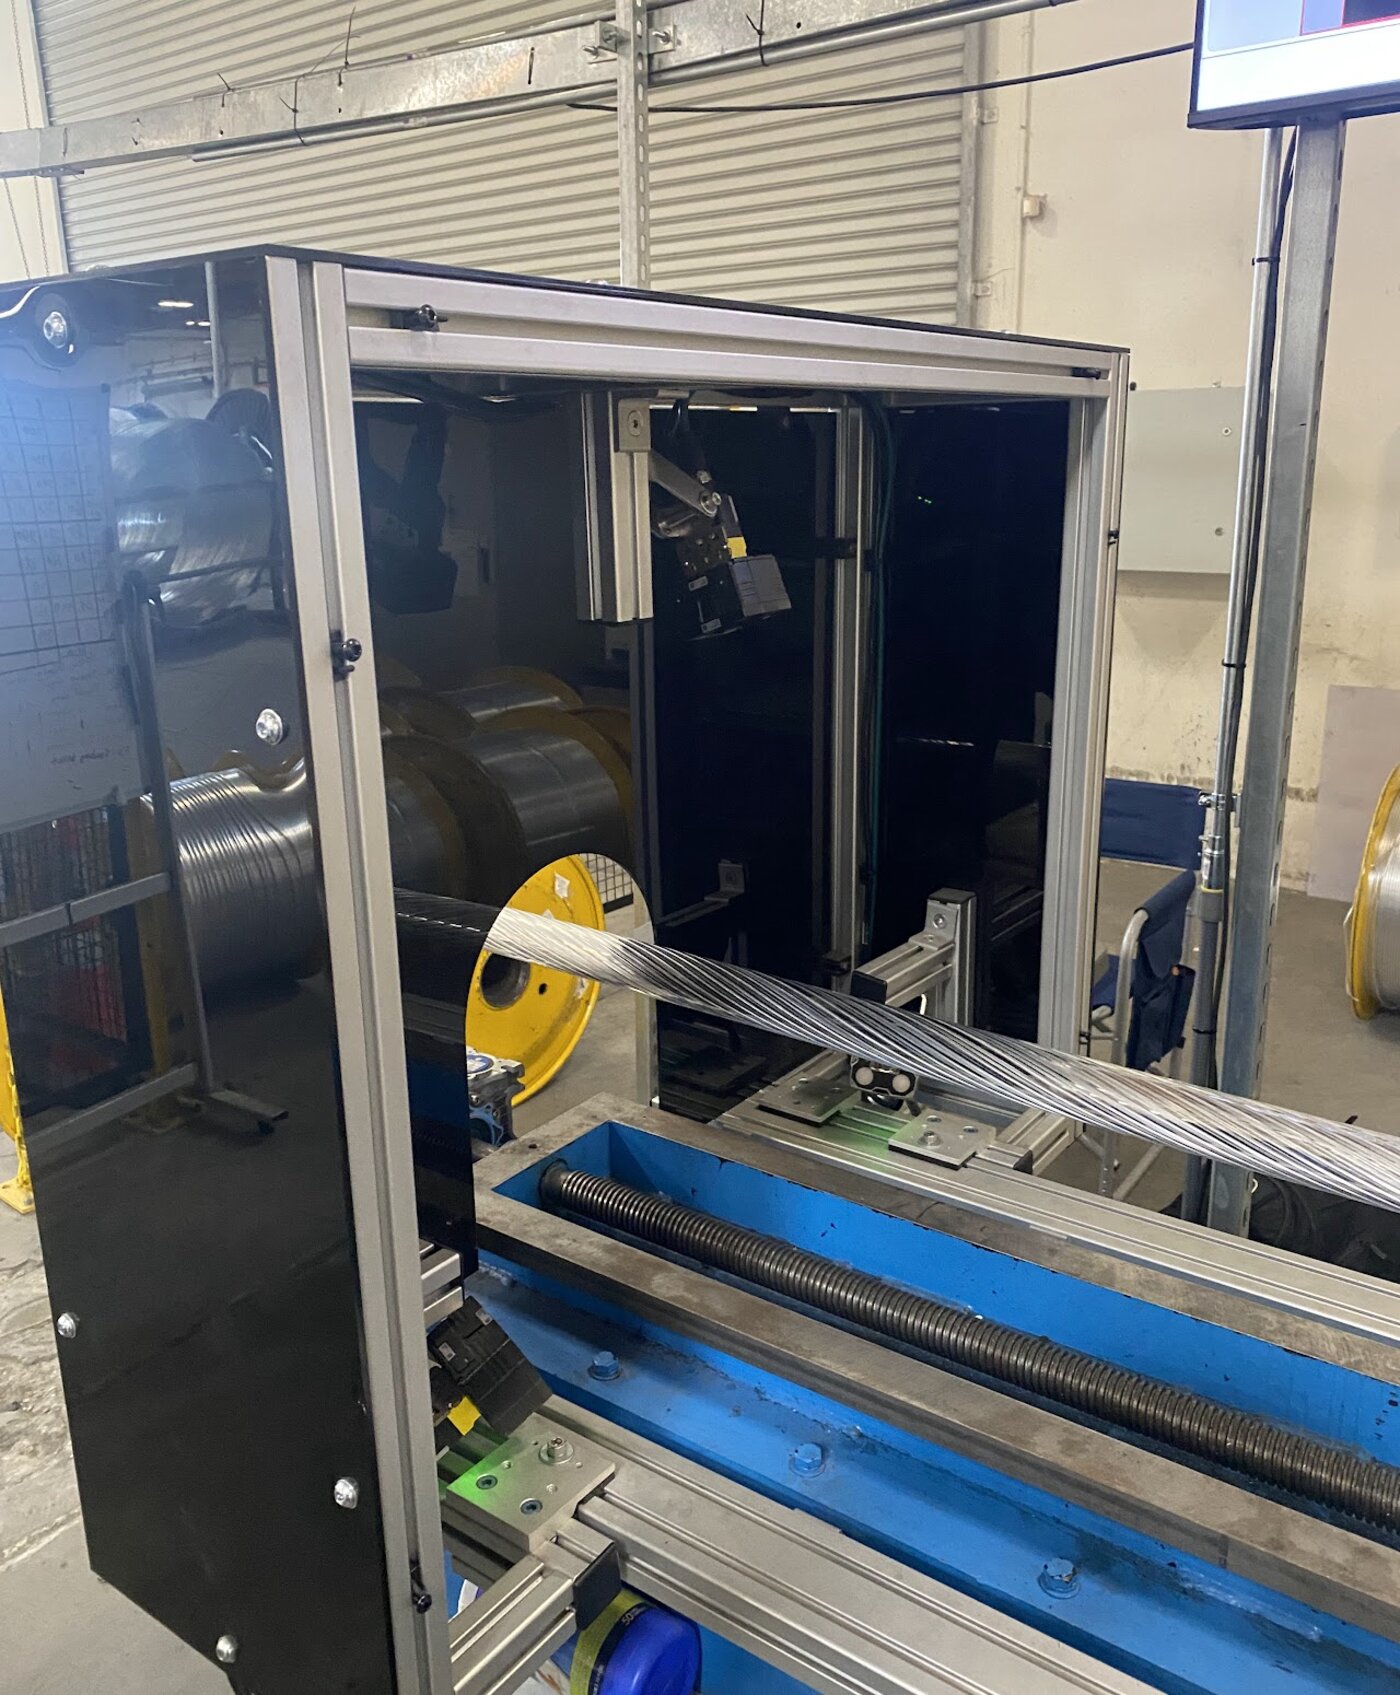
The goal of this design was to create a semi-fixed, yet adjustable 360 inspection for threaded power cable. There are 4 systems with 3 cameras each that are all programmed with deep learning. It utilizes a black polycarbonate shield to block out sunlight that can affect the image the camera sees.
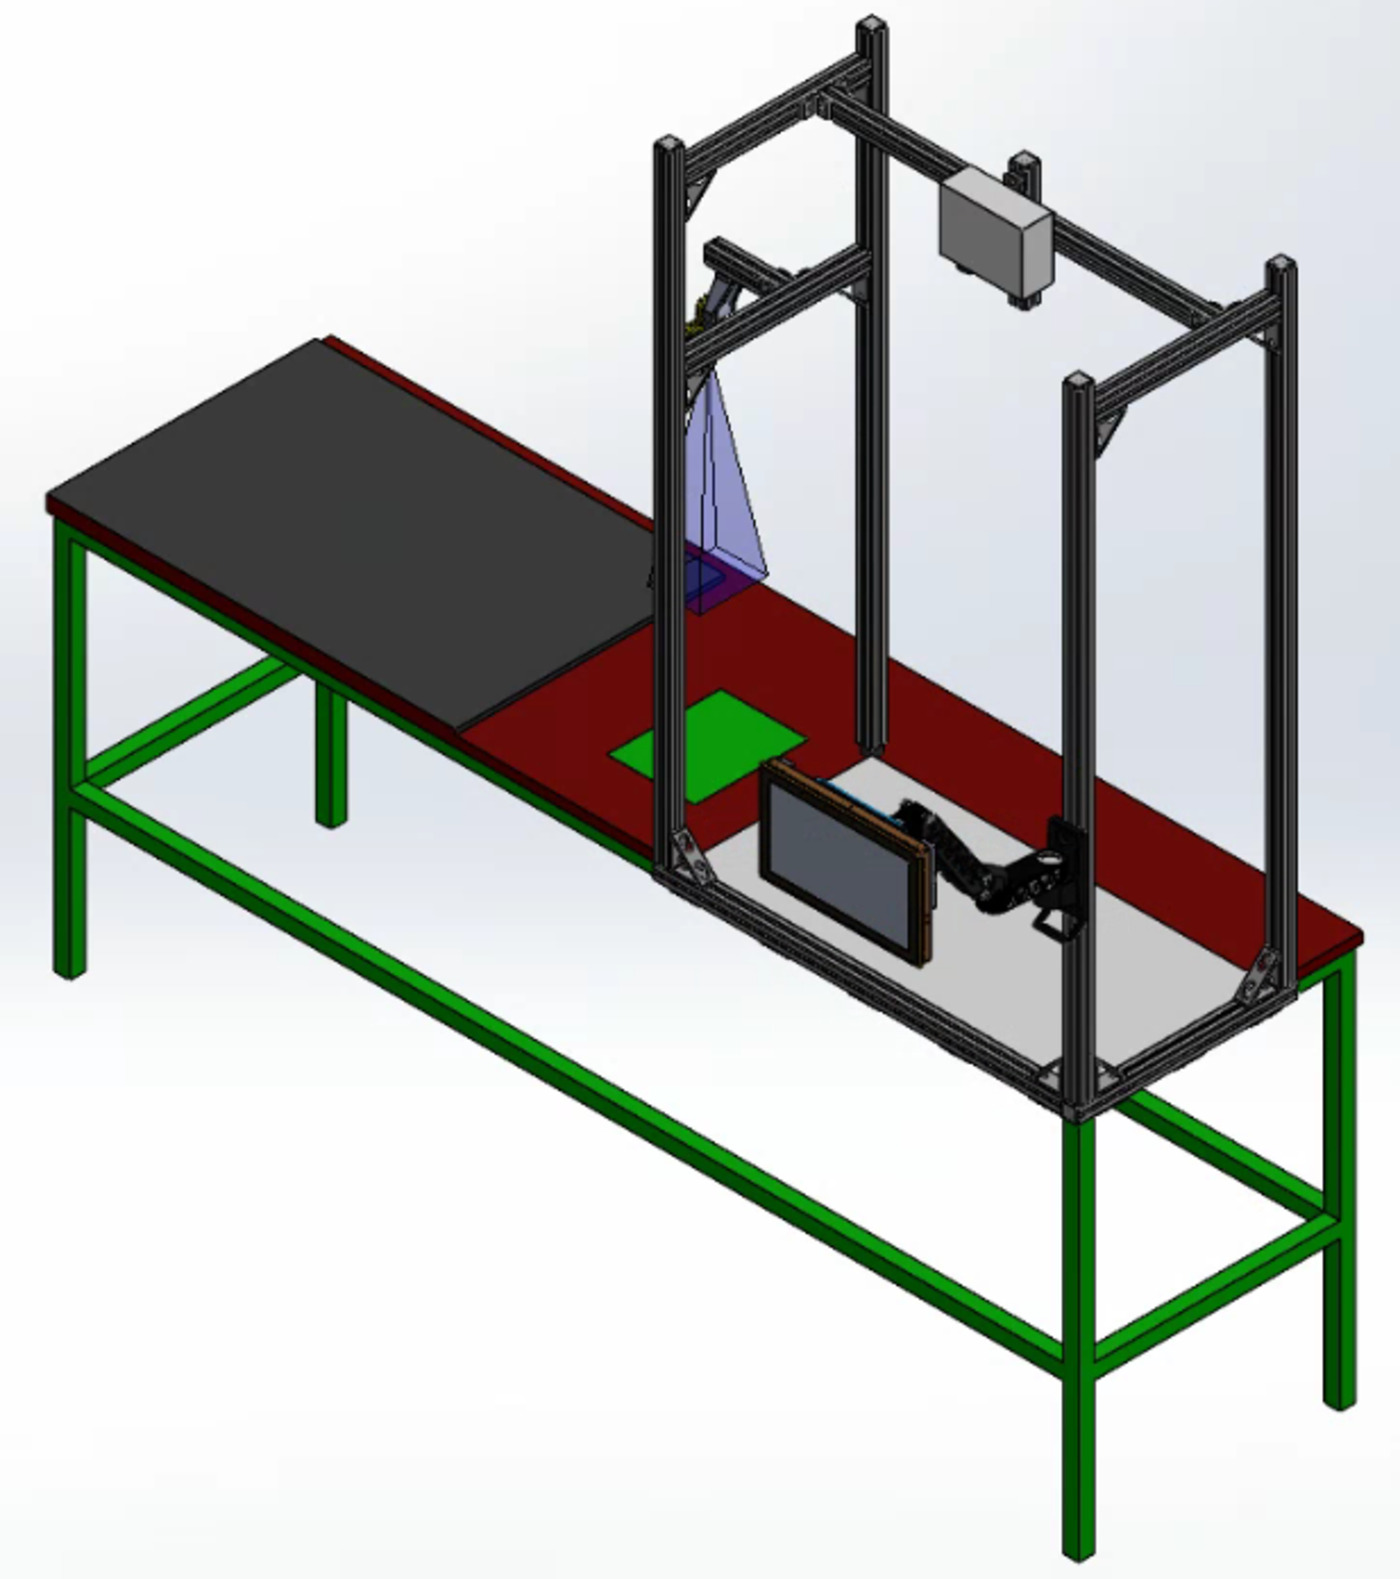
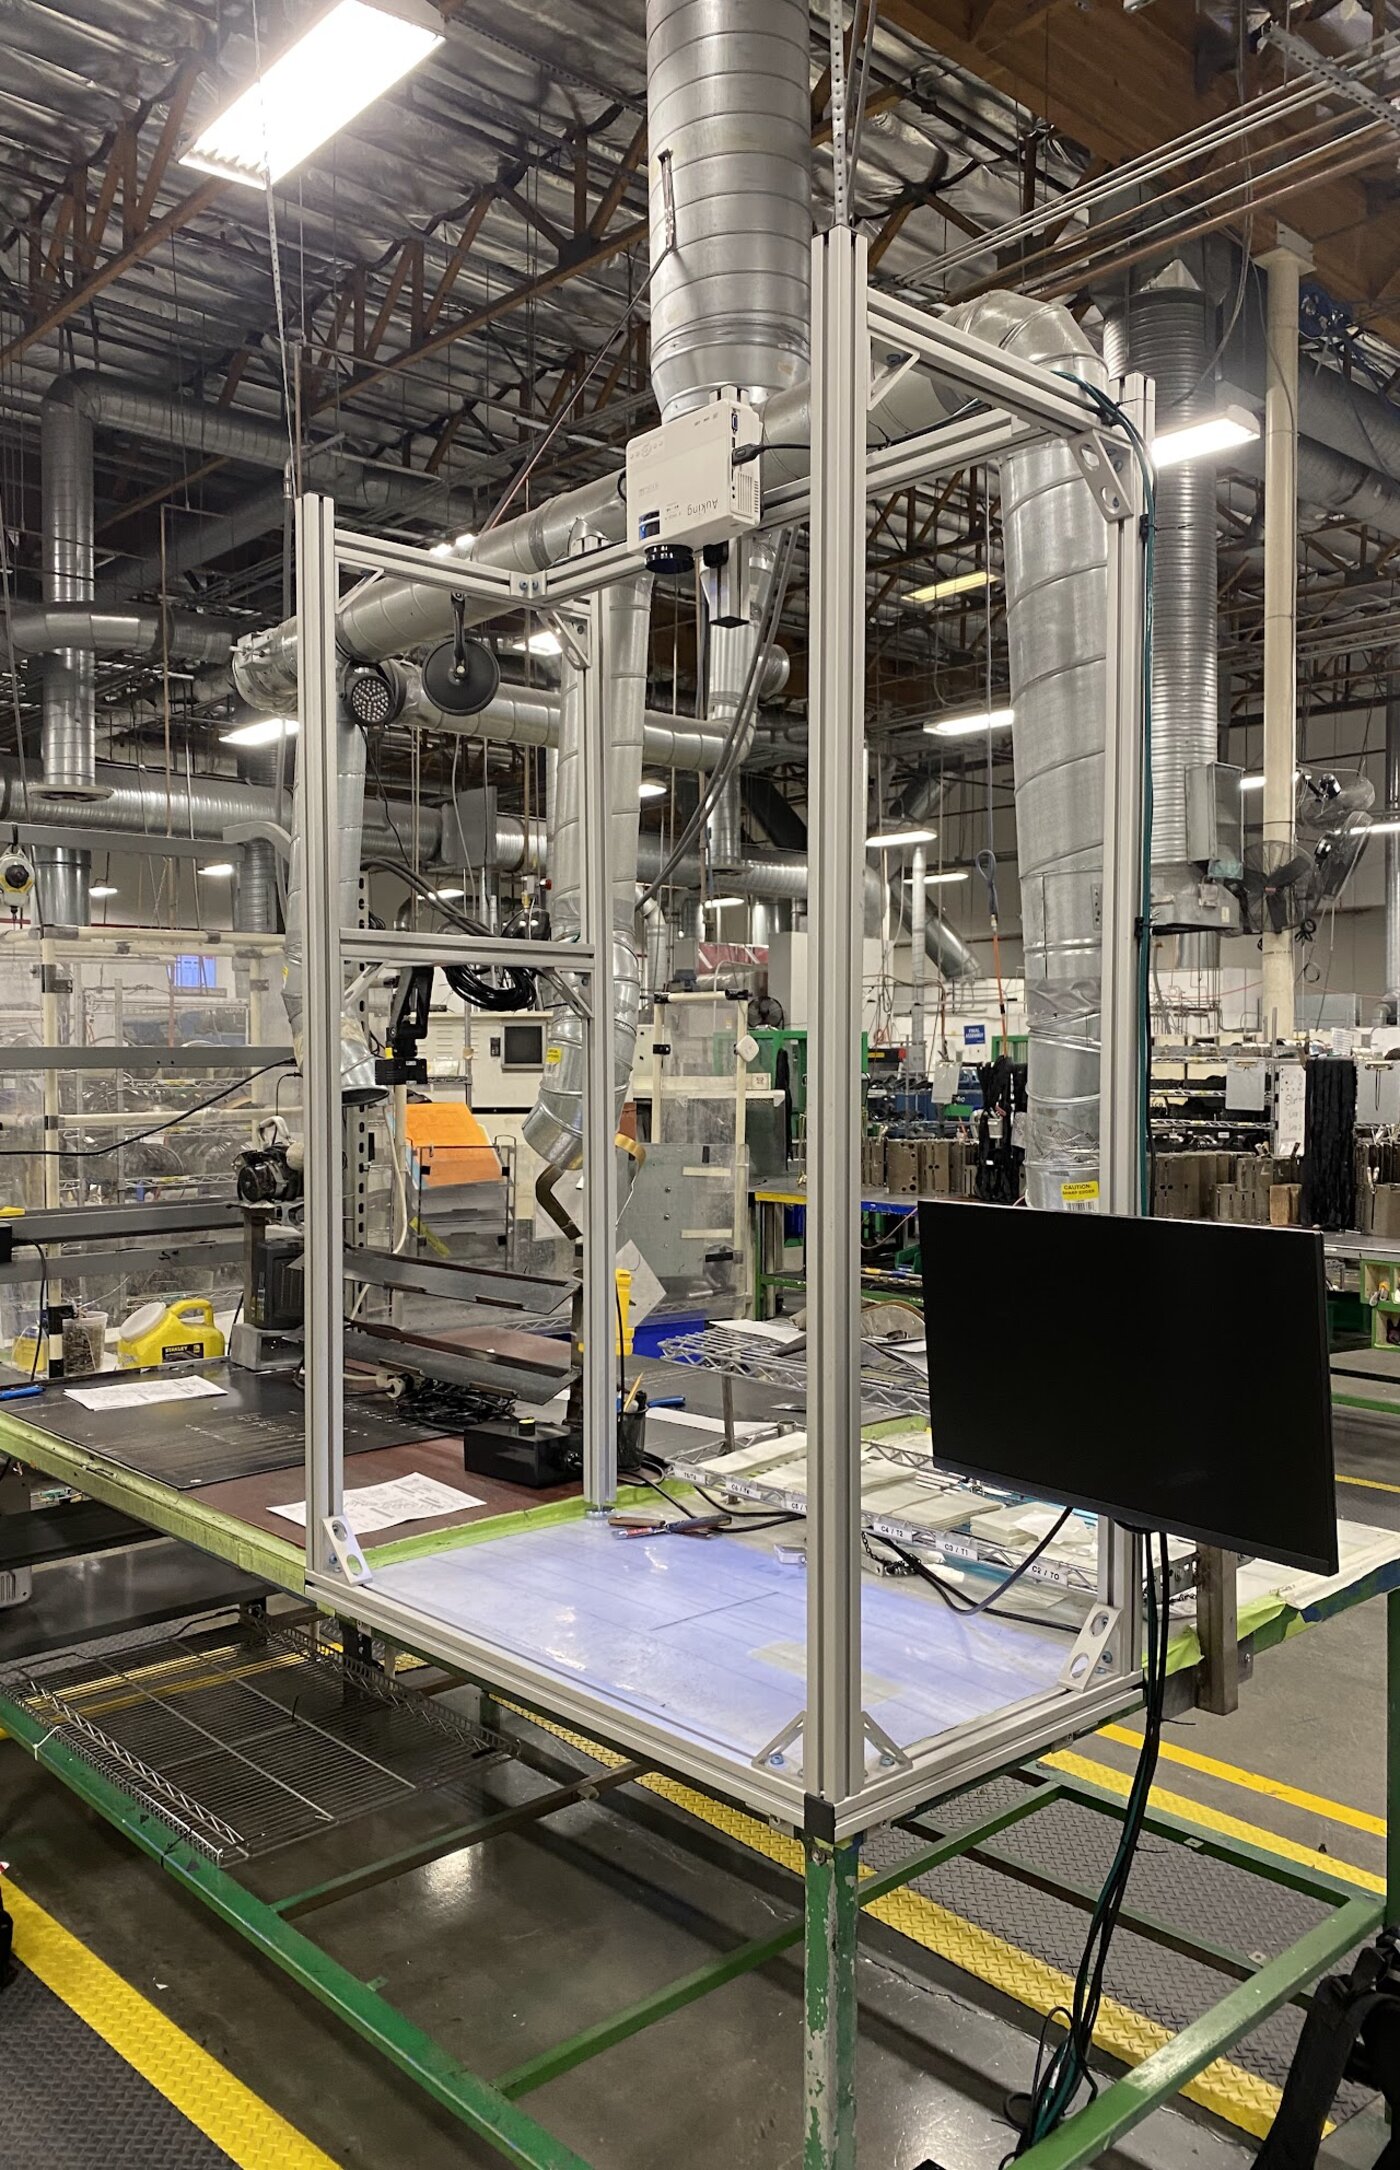
This system utilizes a smart camera, projector, and custom software. I used Python for the programming to capture the FTP data from the camera. The camera uses OCR to capture the data from the work order the operator uses. The projector then displays the dimensions for aligning the carbon fiber layup based on the data in the work order.
Demo video of the camera + projector guided-layup system in action.