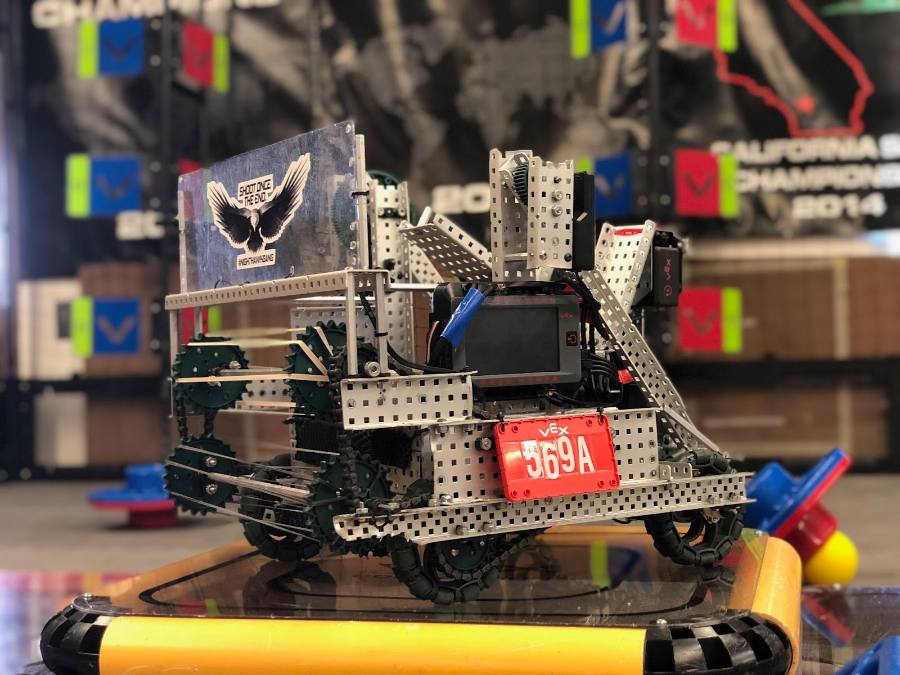
This was the first Iteration of our robot. It utilized 12 motors to use mechanisms like intake to capture balls, a double catapult to launch balls, as well as 6-wheel drive to climb platforms. There were a multitude of sensors for driver feedback as well as autonomous driving features. This robot took us to the final leaderboard of the state championship, as well as us to the 2019 vex world championship involving 584 teams worldwide.
This is the second version of our robot, utilizing stronger motors, a more optimized design, and embedded sensors. Not only can the robot launch balls and climb, but it could also score points by lifting objects with an arm. Furthermore, this robot had consistent autonomous point-scoring utilizing PID-tuned positioning with all of its movements.
This video showcases one of our many autonomous point-scoring sections. We flip caps and shoot, while our teammates from our school park. PID controls with a predefined settling time are used here for positioning.